- Incoming
Research Assistant
Demonstration-Based Robot Learning for Industrial Manipulation
January 2027 · Ottawa, Ontario
- Now
- Robotics Engineer @ WATonomous, imitation learning on a simulated humanoid
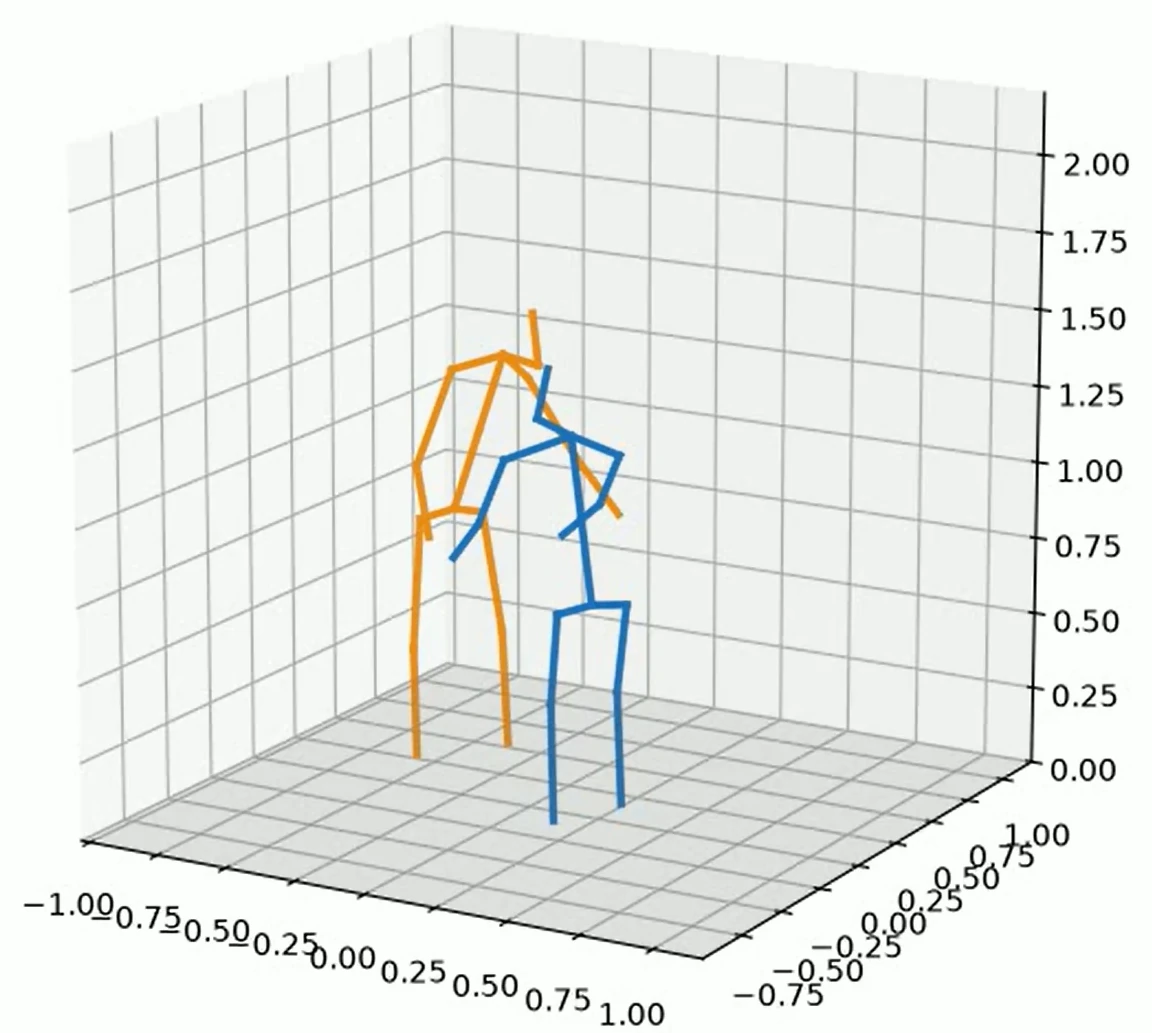
- Perception researcher @ WATiMAKE, 3D reconstruction of judo throws
- Study
B.A.Sc. Mechatronics Engineering
Expected May 2030
Work
Click a row to read itNotes
Current thinking- 2026.11
Everyone's scaling the policy, nobody's checking the clock
Most of the policy work I read leads with model size and demonstration count. Building the WATonomous ingestion pipeline, I found my episodes were silently corrupting from dropped messages on an under-frequency publisher, and the data looked fine until I checked it. I think demonstration integrity is a bigger bottleneck than parameter count right now, and it stays invisible in benchmarks because the datasets are assumed clean.
Capabilities
- Robotics
- ROS 2MuJoCoGazeboLeRobotMoveItFoxglovePath Planning (A*)Pure-Pursuit ControlKinematics (FK/IK)State Estimation (EKF/UKF)TeleoperationSolidWorks
- Learning
- PyTorchImitation LearningACTQLoRA / LoRAQuantizationHuggingFaceRTMPosePose2SimOpenCVNumPyFFmpeg
- Languages
- C++PythonTypeScriptJavaScriptSQLBash
- Systems
- FastAPIPostgreSQLRedisTemporalDockerAWSCI/CDpytestLinuxGitNext.js
Contact
Open to robotics and research work. Email is fastest.